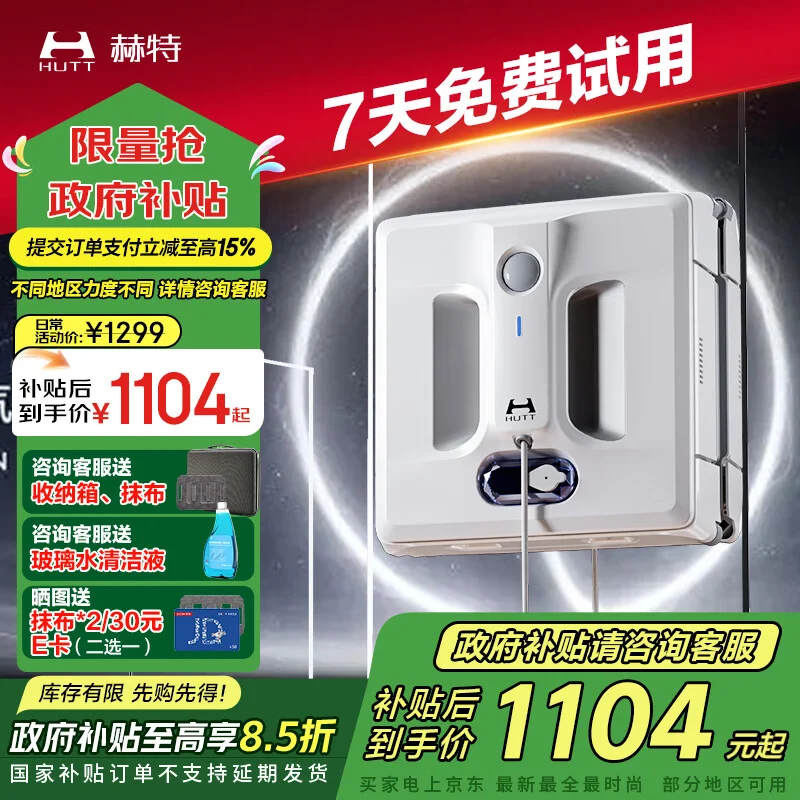
A window cleaning robot holds itself to glass with a vacuum pump at 3.5-4 kPa, drives two belts, and sprays water behind a squeegee; on a skylight the vacuum must overcome the slope, which is why the same design works poorly above 30 degrees.
Strip the plastic off and a window cleaning robot is four systems: vacuum, drive, water, and edge sensing. On a vertical window all four behave well. On a pitched skylight, three of them degrade and the fourth becomes a safety question. Here is what each one actually does.
How does the vacuum hold a robot to glass?
A centrifugal pump evacuates a chamber behind a flexible seal. The pressure difference between atmosphere and chamber is what holds the body up. Typical operating values are 3.5-4 kPa for a 4-5 kg unit on vertical glass, which gives roughly a 1.5-2× margin over the weight it has to carry.
That margin is the whole design. At 3.5 kPa on a 0.05 m² seal area you get about 175 N of holding force, against 49 N of weight for a 5 kg machine. Plenty. Tilt the glass to 30 degrees and the tangential load rises while friction coefficient falls on wet glass, so the usable margin shrinks to something closer to 1.2×. At 40 degrees it is near 1.0×, which is another way of saying it will hold until it does not.
| System | Vertical window | Skylight at 30° | What changes |
|---|---|---|---|
| Vacuum | 1.5-2× margin | ~1.2× margin | Slope adds tangential load |
| Drive | Belt on clean glass | Belt on wet glass | Friction halves |
| Water | Drains down | Runs back into seal | Recovery edge fails |
| Edge sensor | Reads frame | Reads frame or drop | Fall becomes possible |
What drives the robot across the glass?
Two rubber belts, one per side, driven by independent gear motors. Differential speed turns the unit; equal speed drives it straight. The belts are the friction interface, so their condition decides almost everything. Belts with 2 mm of glazing and embedded grit lose grip; belts with algae film lose more. Most “the robot keeps slipping” complaints are belt condition, not suction.
Cleaning path is usually a zigzag: horizontal passes with a fixed overlap of 20-40 mm. On a 1.2 m wide pane a 300 mm brush needs roughly 5 passes per metre of height with 30 mm overlap. That overlap number is where cleaning speed comes from — a 40 mm overlap is 15% slower than 30 mm and produces noticeably fewer streaks.
Why does water behave differently on a skylight?
Because on a vertical pane gravity takes the water down past the squeegee, and the recovery edge collects it. On a 30-degree skylight, water pooling near the lower seal sits against the vacuum lip instead of being collected. Two things follow: streaks near the lower edge, and a seal that is fighting both slope load and a water film.
Purpose-built skylight machines handle this by spraying less and by running a higher squeegee angle so water is pushed sideways toward the drip edge. If you are adapting a window robot for a glass roof, that is the first thing to fail.
How does the robot know where the edge is?
Most units use infrared reflect sensors looking for the frame reflection, with a mechanical bumper as backup. Infrared works on clear glass and fails on tinted, frosted, or low-E coated panes. Some designs add a vacuum-differential sensor: if pressure drops suddenly, the unit is over an edge. That is more reliable and more expensive.
On a skylight the failure mode is worse than a stall. A robot that misses an edge on a window hits the frame. One that misses an edge on a glass roof has a vertical drop in front of it, which is why the tether is not an accesssory. Our Lingyun Y3 review covers obstacle-crossing design for raised seams, and our Lingkong K3 review is the closer read for pitched high-rise facade work.
Does the mechanism tell you who should buy?
Yes, in a rough way. If your glass is flat, vertical, framed and between 1 and 30 m² per pane, the four systems above all work as designed and a robot is a reasonable buy. If your glass is pitched past 30 degrees, frameless, or smaller than 400 mm in one dimension, you are asking the design to do something it was not built for.
That second group needs a purpose-built unit or a crew. All robot reviews on this site list pitch limits and edge-sensing type per model, which is the fastest way to check where a candidate actually sits.
What fails first in the mechanism?
Seals, then belts, then the pump. A seal that has taken a set does not announce itself — the pump just runs longer to hold the same vacuum, and on a window that is inaudible over traffic. On a skylight it becomes audible because the pump is fighting a slope. Rough order of service life: seal 800-1,200 hours, belts 1,200-1,800 hours, pump 2,500-3,500 hours.
The firmware matters more than buyers expect. Edge detection thresholds are set per glass type at manufacture, and on low-E coated glass with 4% reflectance those thresholds can read a reflection as a frame. Units that let the installer adjust sensitivity on site avoid this. Units that do not, need a firmware update or a different glass strategy.
Key Takeaways
- Vacuum margin falls from roughly 1.5-2× on a vertical pane to about 1.2× on a 30-degree skylight.
- Belt friction is the real cause of most slipping complaints; algae film cuts it more than seal wear does.
- A 30 mm pass overlap is about 15% faster than 40 mm and still leaves fewer streaks than a 20 mm overlap.
- On pitched glass water pools against the lower seal, so recovery fails before suction does.
- Infrared edge sensing fails on tinted and low-E glass; always pair it with a mechanical bumper and a tether.